This post is also available in:
 עברית (Hebrew)
Making drones smaller creates an awkward navigation problem. Cameras become unreliable in darkness, smoke and dust, while LiDAR sensors and the processors needed to interpret their data can be too heavy and power-hungry for aircraft weighing less than 100 grams. In exactly the environments where a tiny drone could be most useful, it may therefore struggle to see where it is going.
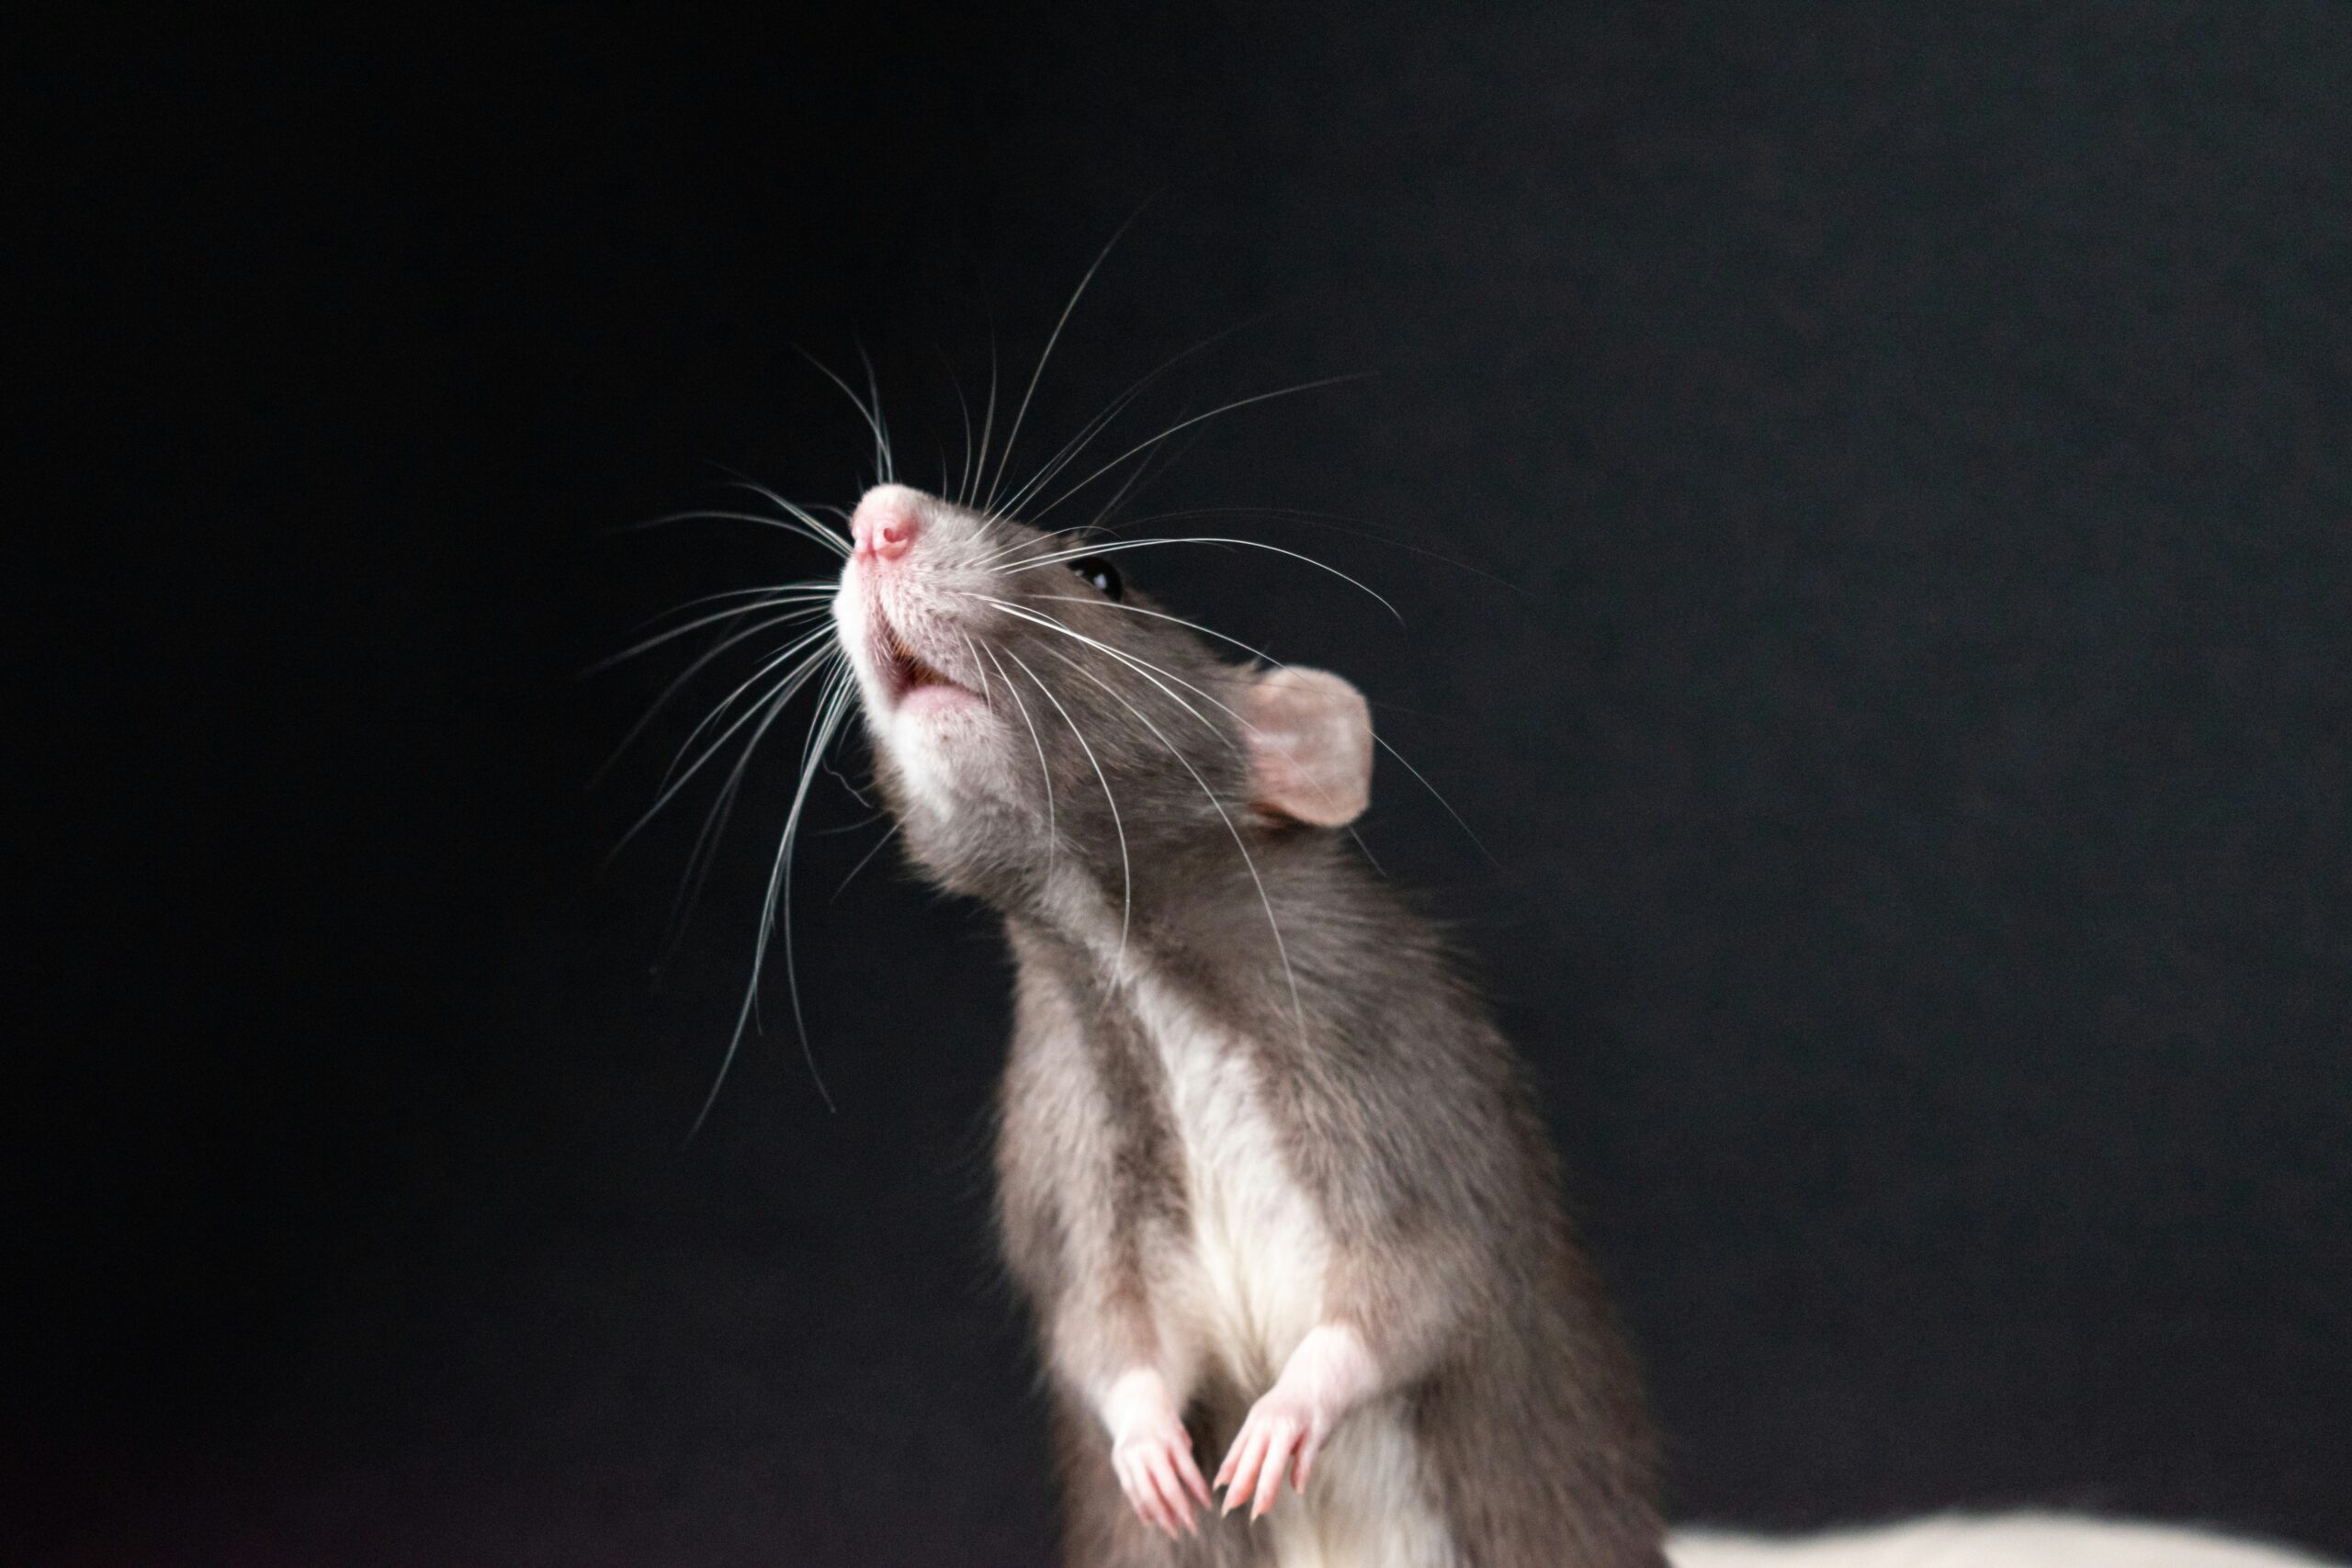
Researchers at Delft University of Technology have developed a different solution: give the drone whiskers.
Inspired by rodents, the system uses two flexible artificial whiskers mounted at the front of a micro-drone. Instead of visually observing obstacles, the aircraft physically touches nearby surfaces and uses the resulting movement of the whiskers to determine their location.
Rodents use their whiskers, or vibrissae, to navigate confined environments where vision is limited. When a whisker contacts a surface, tiny changes at its base provide information about the object’s position. The drone applies a similar principle electronically.
Each artificial whisker has three miniature pressure sensors at its base. When the flexible structure bends against a wall or another object, those sensors measure the resulting pressure changes. The system then calculates the location and depth of the contact in three dimensions, providing immediate information about the drone’s surroundings.
According to Interesting Engineering, one of the main engineering challenges came from the aircraft itself. Propellers generate airflow and vibrations that also bend the whiskers, potentially making it difficult to distinguish an actual obstacle from the drone’s own aerodynamic disturbance.
The researchers developed an onboard processing method that continuously filters out this self-generated noise. Despite producing millimeter-scale depth information, the algorithm requires only 34 kilobytes of memory, keeping its computing requirements suitable for very small aircraft.
During flight tests, whisker-equipped drones successfully operated inside completely dark environments without visual information. They mapped previously unknown room layouts, followed surface contours and located exits using tactile feedback.
The approach could be particularly useful for search-and-rescue operations. Micro-drones could enter collapsed or smoke-filled structures where larger robots cannot fit and conventional cameras provide little useful information. Similar systems could inspect pipes, ventilation ducts, sewers, mines and other confined infrastructure.
There are also potential defense and homeland-security applications. Small tactile drones could explore damaged buildings, tunnels or enclosed spaces before personnel enter, providing information from environments where darkness, smoke or airborne debris limits optical sensors.
The system is not intended to make cameras obsolete. Instead, touch provides another sensing method for conditions in which sight stops working.
For tiny autonomous aircraft, that could be particularly valuable: rather than carrying increasingly sophisticated equipment to see through the darkness, sometimes the lighter solution is simply to reach out and feel the wall.
The research was published here.